Xintong Zhang
Hi, I’m Xintong Zhang, a senior undergraduate student majoring in Applied Mathematics and Computer Science at Duke Kunshan University.
I am currently conducting research on Vision-Language Navigation, collaborating with Dr. Kunhui Wang, Prof. Junyu Gao, Prof. Changsheng Xu, and their team from the Institute of Automation, Chinese Academy of Sciences.
Previously, I worked on Multi-Agent Collaboration, under the supervision of Dr. Junfeng Chen, Prof. Meng Guo from Peking University.
My research interests lie at the intersection of Embodied AI, Multimodal Learning, and Robotics. I am particularly interested in developing intelligent agents capable of perceiving complex environments, reasoning about future states, and making reliable decisions. My current research focuses on Vision-Language Navigation and Learning-based Planning, with previous experience in LLM based Multi-Agent Coordination and Collaboration.
Publication
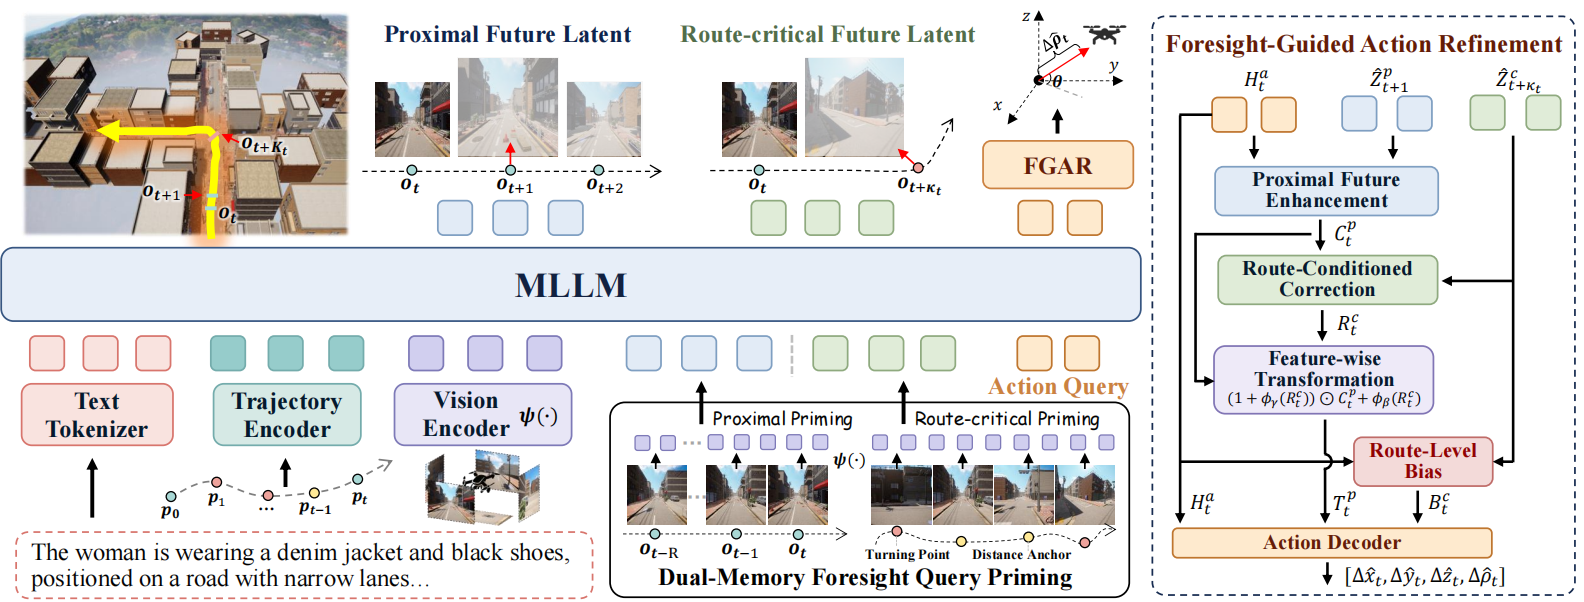
Kunhui Wang*, Xintong Zhang*, Junyu Gao, Changsheng Xu
Submitted to ICLR 2027
Paper
Overview: We propose ForeFly, a dual-horizon latent world action model for aerial VLN. It predicts both a proximal future for local continuity and an adaptive route-critical future for long-range guidance. We design visual memories to provide history-aware context for future prediction, and we also introduce Foresight-Guided Action Refinement to exploit proximal foresight for local action enhancement and route-critical foresight for route-level guidance. The method is validated on the TravelUAV and UAV-ON benchmarks, showing that ForeFly consistently outperforms strong baselines across seen and unseen settings.
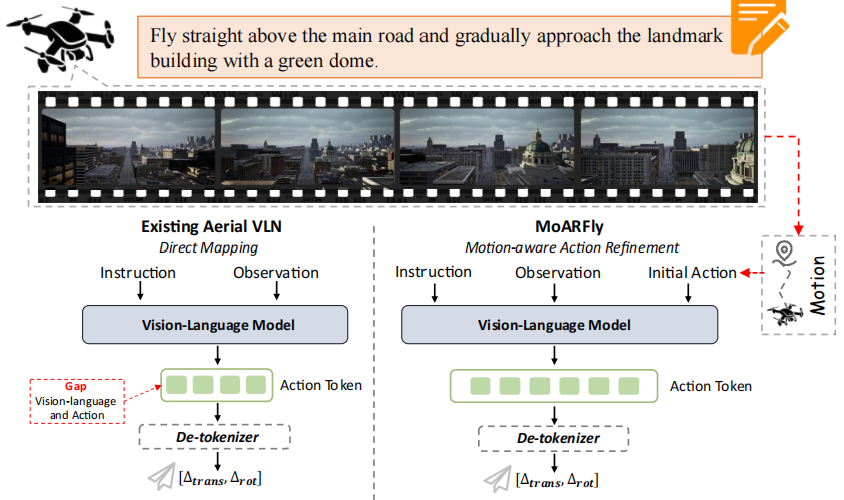
Kunhui Wang, Xintong Zhang, Yufan Hu, Yang Yang, and Junyu Gao
Submitted to TMM
Overview: We propose MoARFly, a motion-aware action refinement framework for aerial Vision-Language Navigation (VLN). By introducing a Dual-Query Transformer to capture inter-frame motion dynamics and progressively refine action representations, MoARFly bridges the gap between visual-language understanding and executable actions. Extensive experiments on OpenFly and TravelUAV demonstrate improved navigation accuracy, efficiency, and generalization to unseen environments.
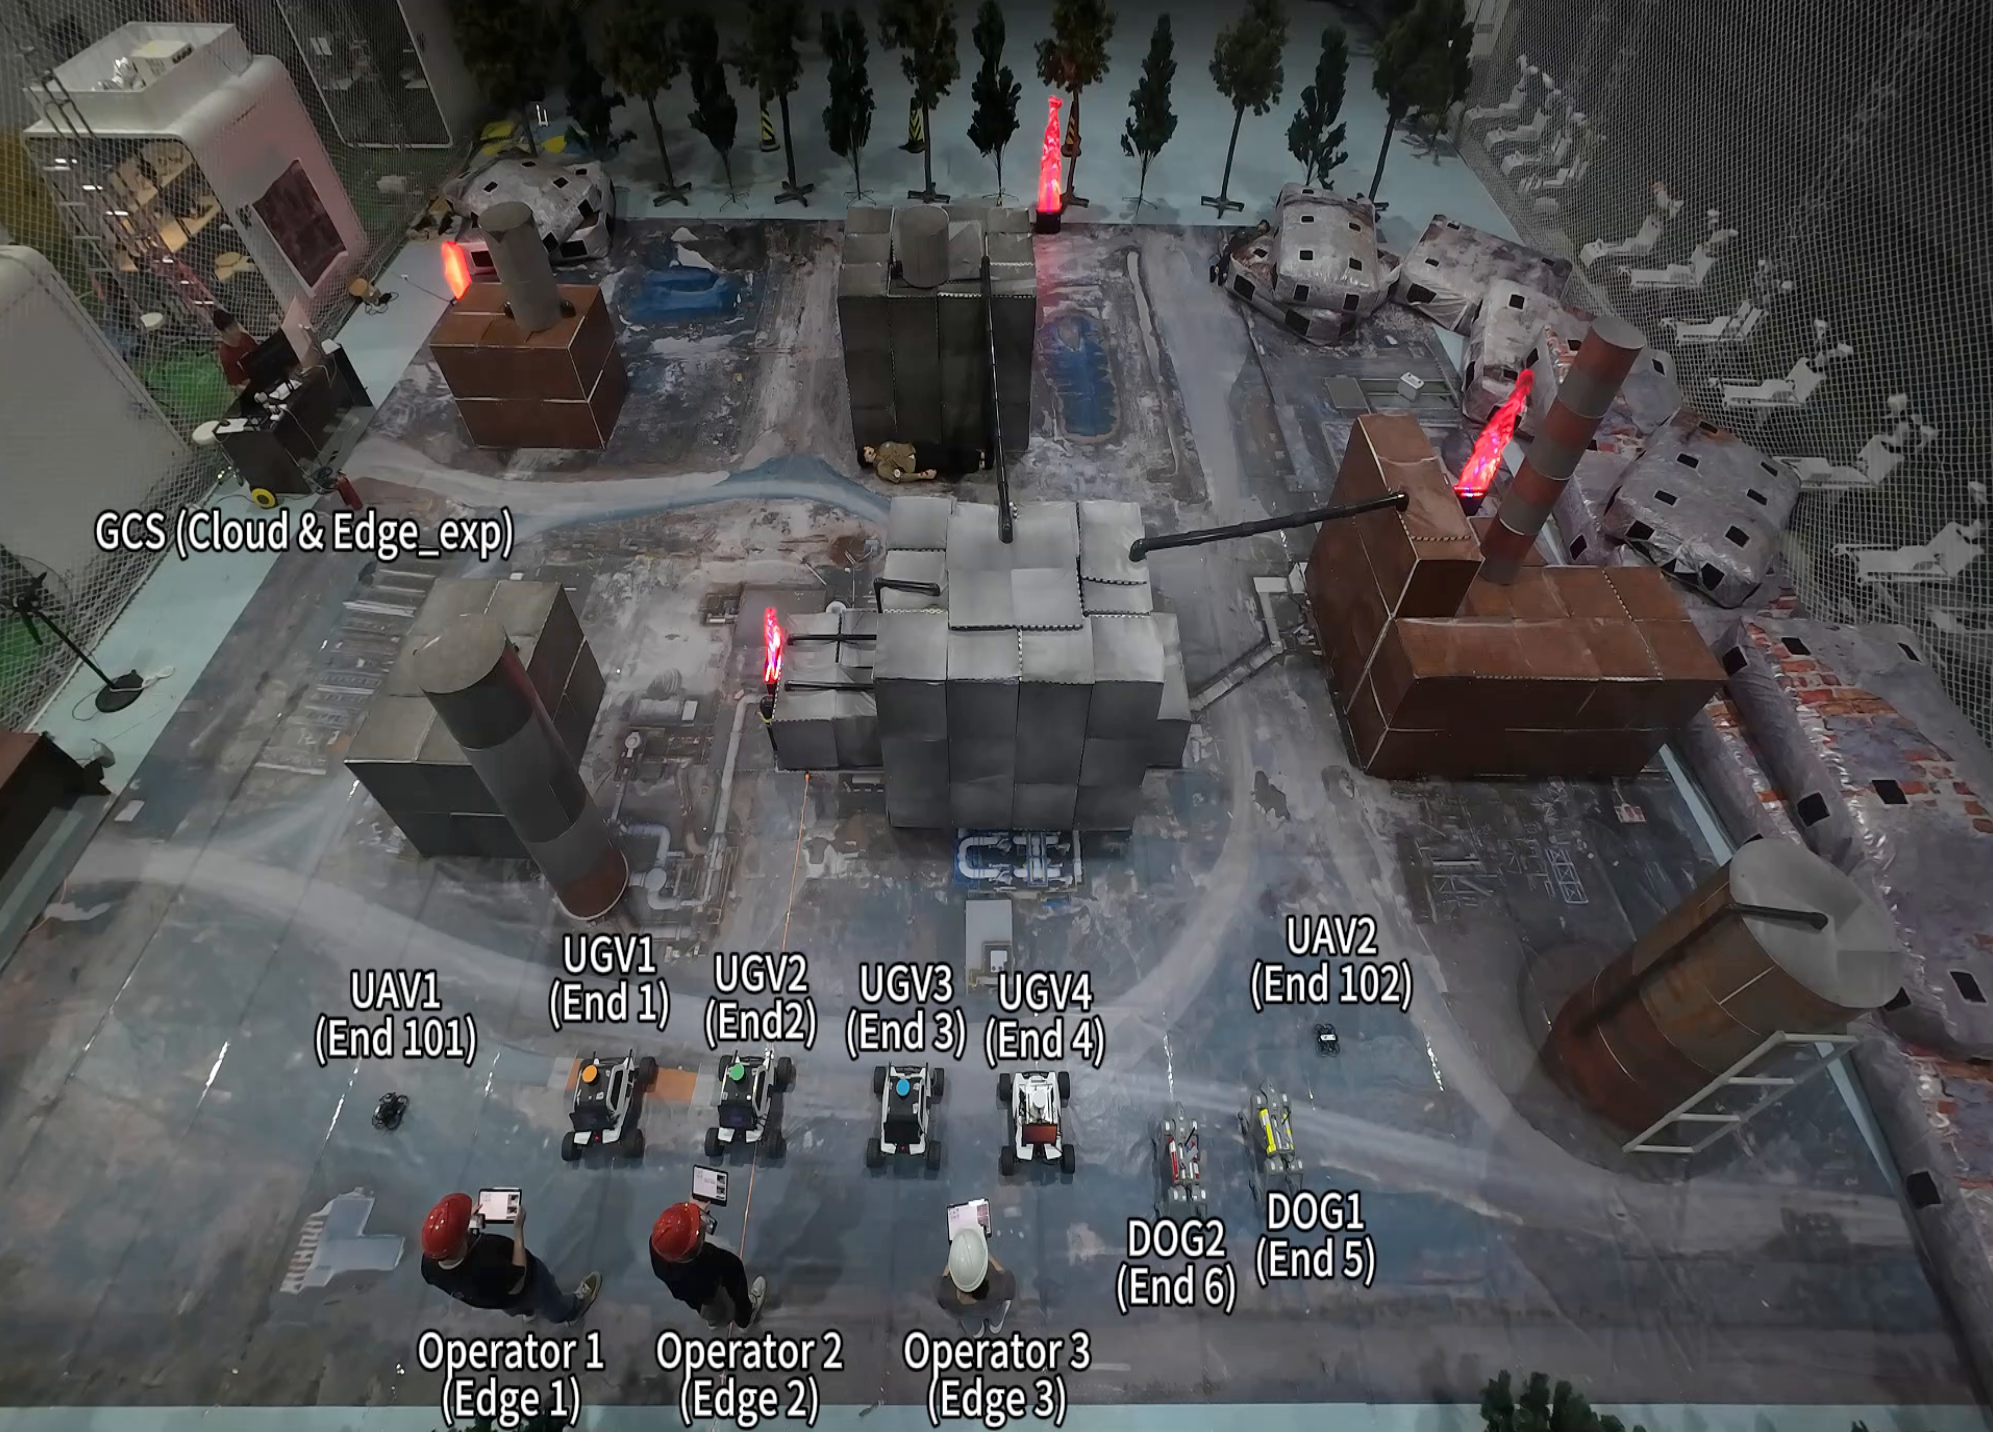
Junfeng Chen, Yuxiao Zhu, An Zhuo, Xintong Zhang, Shuo Zhang, Meng Guo, and Zhongkui Li
Submitted to npj Robotics
Paper Video Website
Overview: We propose a formal method and LLM framework for coordinating large fleets of heterogeneous robots in open and dynamic environments. Our approach integrates model-checking-based task planning with LLM-powered reasoning and interaction, ensuring adaptability, explainability, and optimal mission execution. Validated through simulations and real-world deployments, it proves effective for disaster response, infrastructure inspection, and dynamic surveillance.
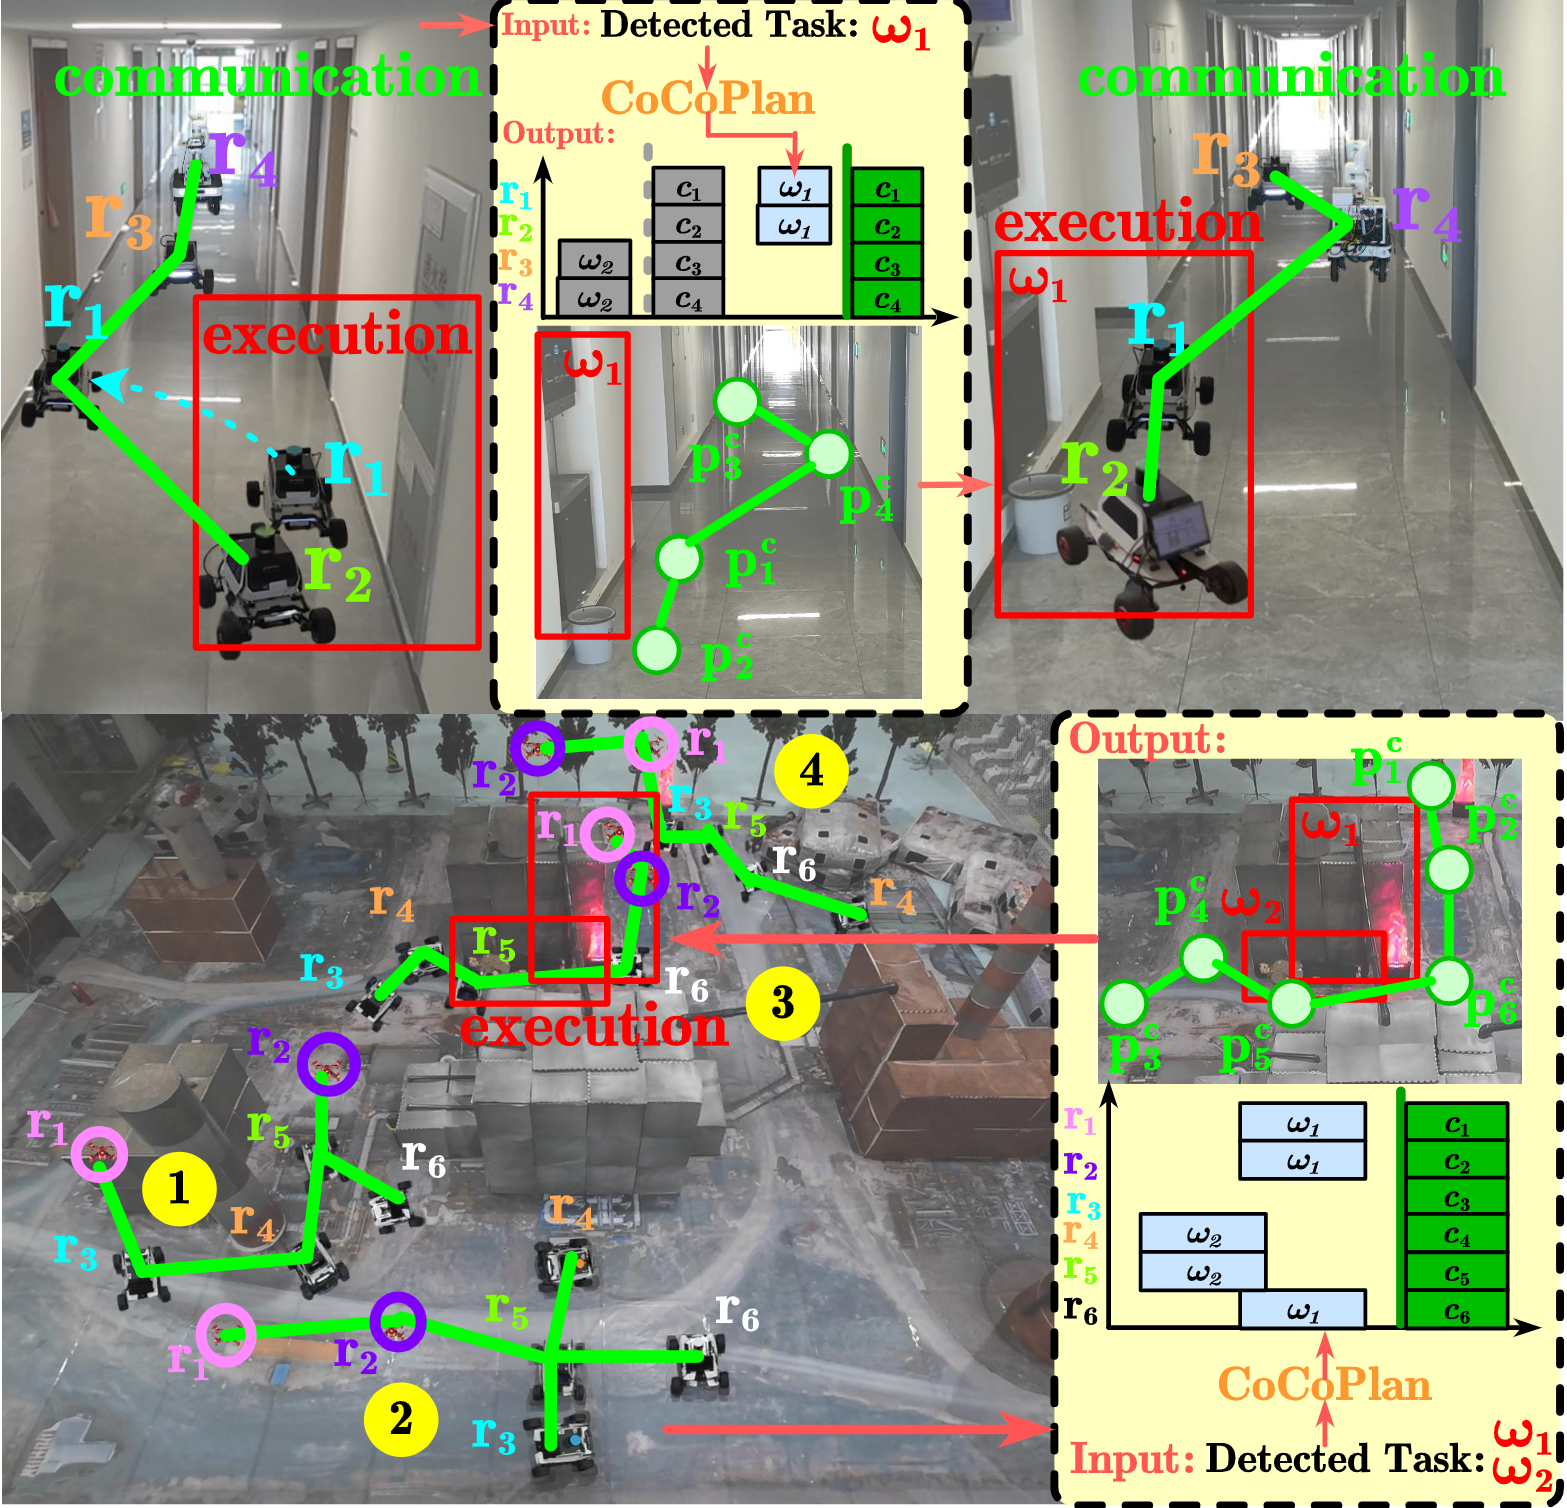
Xintong Zhang*, Junfeng Chen*, Yuxiao Zhu, Bing Luo, Meng Guo
Robotics and Automation Letter (RA-L), 2026
Paper Video Website
Overview: We propose CoCoPlan, a collaborative framework addressing communication-aware task planning for multi-robot systems under intermittent connectivity constraints. The framework focuses on joint optimization of communication events and task allocation, ensuring robustness in unknown environments.
Yuxiao Zhu*, Junfeng Chen*, Xintong Zhang, Meng Guo, Zhongkui Li
IROS 2025
Paper Video Website
Overview: We propose DEXTER-LLM, a novel framework for dynamic task planning in unknown environments. Our approach integrates LLM-based multi-stage reasoning, optimization-based task assignment, and adaptive human-in-the-loop verification to tackle the challenges of online adaptability and explainability.

Junfeng Chen, Yuxiao Zhu, Xintong Zhang, Bing Luo, Meng Guo
Transactions on Automation Science and Engineering (TASE), 2025
Paper Website
Overview: We propose SLEI3D, a planning and coordination framework for heterogeneous multi-robot systems to perform simultaneous 3D exploration, inspection, and real-time reporting in unknown environments. Our approach integrates adaptive inspection and intermittent communication protocols with a multi-layer, multi-rate planning mechanism for robust coordination.
Experiences
Research Internship, 2024.04-Present
Supervisor: Dr. Kunhui Wang, Prof. Junyu Gao, Prof. Changsheng Xu
Exchange, 2025.08-2025.12
Research Internship, 2024.05-2026.02
Supervisor: Dr. Junfeng Chen, Prof. Meng Guo
Honors and Awards
[2024.04] National-Level College Student Innovation and Entrepreneurship Project
[2025.04] Student Experiential Learning Fellow (SELF) – Duke Kunshan University
[2025.04] Signature Fund (SF) – Duke Kunshan University
[2025.12] National Encouragement Scholarship - Jiangsu Provincial Department of Education
[2023-2026] Dean’s List – Duke Kunshan University
Services
Reviewer: RAL
Conference Participation: IROS 2025, ICRA 2026
Teaching Assistant: DKU COMPSCI101: Introduction into Computer Science (2024 Fall)
CV
See here